Detecting a target at a sensor's catalogue distance does not guarantee reliable sensing on every machine cycle. Target material, surface, approach, contamination and connection type can affect the result. Correct selection begins by defining the object to be detected and the production impact of false detection.
01Which characteristic of the target are we detecting?
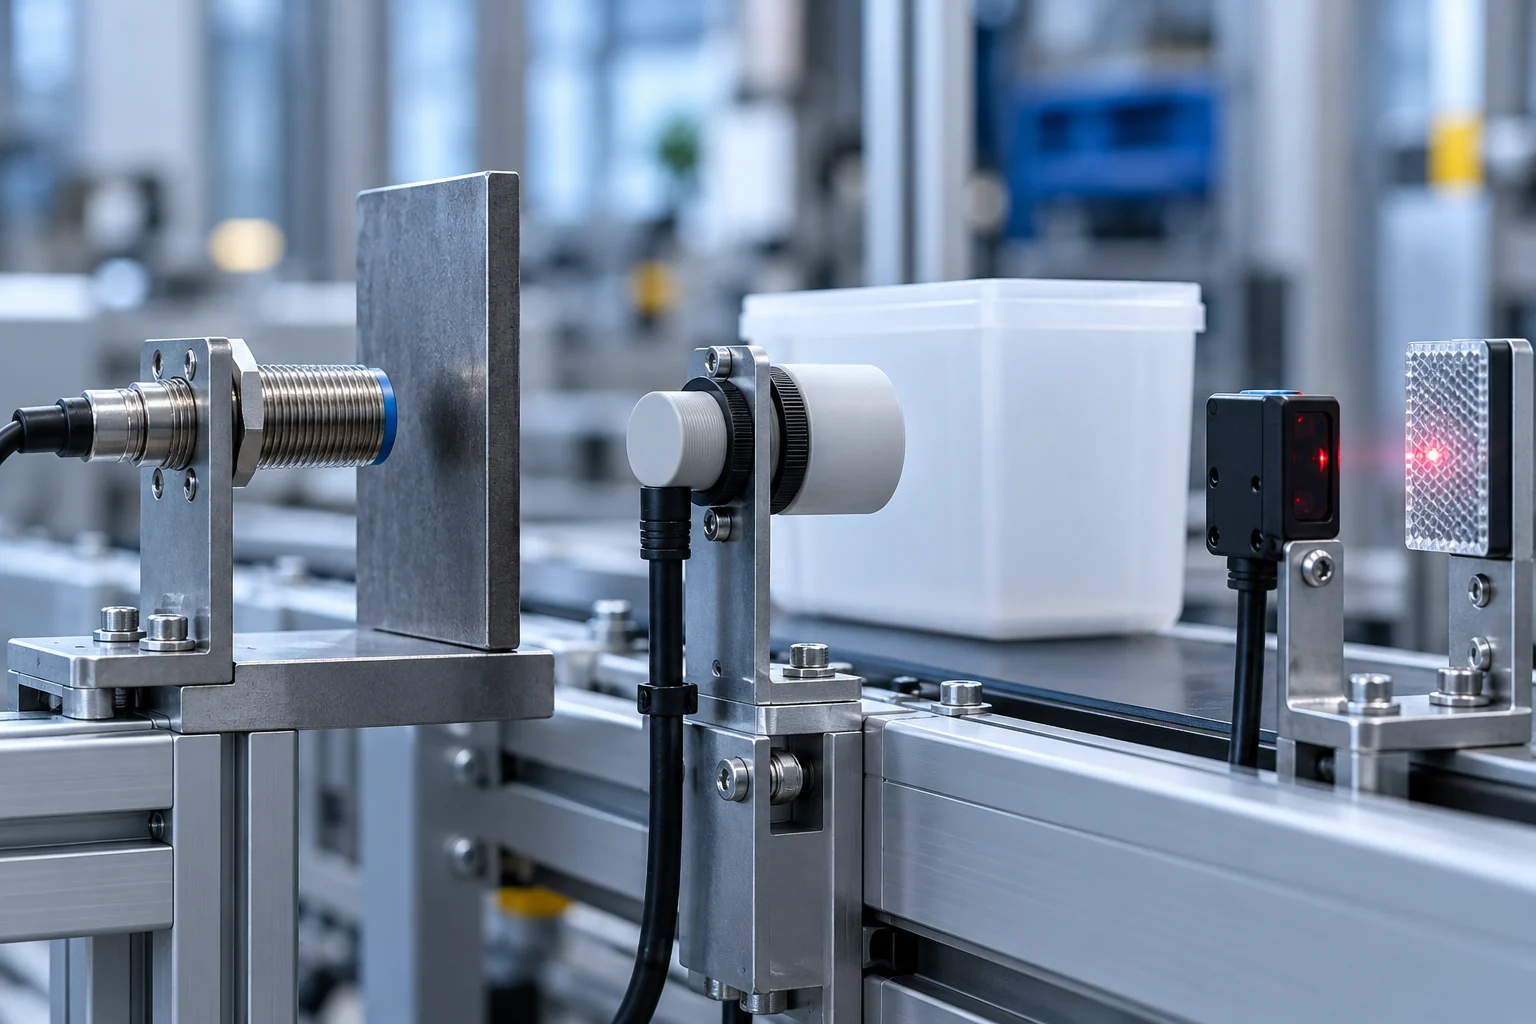
Inductive sensors are considered for metal targets. Capacitive sensors respond to changes in a material's electrical properties and can be used for targets such as liquids or plastics. Photoelectric sensors use light and are available in through-beam, retro-reflective and diffuse arrangements. These technologies are not simply versions of one another with different sensing distances.
Detecting the presence of a metal part and counting transparent bottles, for example, are different selection problems. Colour, gloss and transparency can affect an optical method. Consider humidity and surrounding deposits for capacitive sensing, and metal type and mounting geometry for inductive sensing.
02Do not use the nominal sensing distance as the operating point
Catalogue sensing distances are specified for particular standard targets and test conditions. Available distance may change if the actual target is smaller, made of another metal or approaches at an angle. Verify the reliable sensing range using the manufacturer's definition and application tests.
Mechanical tolerances must also be included. Target movement, flexing sensor brackets or accumulated swarf can destabilise a selection operating near its limit. A robust design does not push the sensor to its maximum possible distance; it leaves a repeatable operating margin.
| Application | Initial candidate | Point requiring particular verification |
|---|---|---|
| Presence of a metal part | Inductive | Metal type, target size and mounting clearance |
| Level detection in a plastic container | Capacitive | Wall thickness, product and humidity changes |
| Counting boxes on a conveyor | Photoelectric | Target range, surface and response time |
| Transparent packaging | Suitable optical arrangement | Manufacturer suitability for transparent targets |
03Is the electrical output compatible with the PLC?
Select PNP/NPN, NO/NC and two-, three- or four-wire arrangements together with the input module. The same connector does not imply the same pinout or function. Compare supply range, output current, leakage current and input detection thresholds.
The choice of normally open or normally closed output relates to the required failure behaviour. Using an NC output on an ordinary sensor does not make it a safety sensor, however. Detection used for personnel safety must be addressed separately using suitable safety components and architecture.
04Do not limit speed calculations to the sensor alone
The time a target remains within a conveyor's sensing zone depends on target length and speed. For example, a 20 mm target travelling at 1 m/s has a theoretical passage time of 20 ms. Sensor response, input filtering and the PLC's sampling method must be fast enough within this window. Mechanical shape and optical spot size can change the actual pulse.
Solving the problem solely by reducing the PLC input filter can increase susceptibility to interference pulses. Consider a hardware counter or a different target arrangement if necessary. A sound selection verifies the sensor and control chain together.
05Environment and mounting are not minor details
The IP rating, temperature range, cleaning-chemical resistance and cable sheath must suit the application. Washdown conditions on a food production line are not equivalent to a dry workshop. Also assess mechanical impacts and how sensor adjustment will be maintained during servicing.
Test contamination and background effects for optical sensors, alignment for through-beam arrangements and reflector suitability for retro-reflective arrangements. Follow flush or non-flush mounting instructions for inductive sensors. Ignoring the manufacturer's clearances around metal can change the sensing distance from the bench-test result.
06Validate the selection with actual target samples
- Test the smallest, darkest / brightest or most transparent target sample.
- Record the pulse at minimum and maximum speed.
- Include normal contamination and mechanical tolerances in the test plan.
- Check that cable disconnection and sensor faults are clearly indicated on the HMI.
- Record the model, connections and final settings in the maintenance documentation.
A sensor is not merely a catalogue product; it becomes a reliable measurement chain when the target, mounting and software work together.
07Example verification scenario
Consider an optical sensor that counts most boxes but misses some in a dark-coloured product batch. The first step is not to turn sensitivity to maximum, but to examine the actual sensing arrangement together with the target surface and background. Test the most difficult product sample at minimum and maximum speeds. Verify the final setting with contamination and mechanical tolerances taken into account. Even if the sensor model remains unchanged, record results by product to provide a reference for future changeovers.
Technical references and further reading
For product- and version-specific values, the relevant manufacturer's current documentation should be taken as the reference. The calculations and scenarios above are engineering examples for illustrative purposes.